

 Bahasa Indonesia
 Deutsch
 English
 Español
 Français
 Português (Brasil)
 Türkçe
 ไทย
 中文(繁體)
 日本語
 한국어
距离传感器
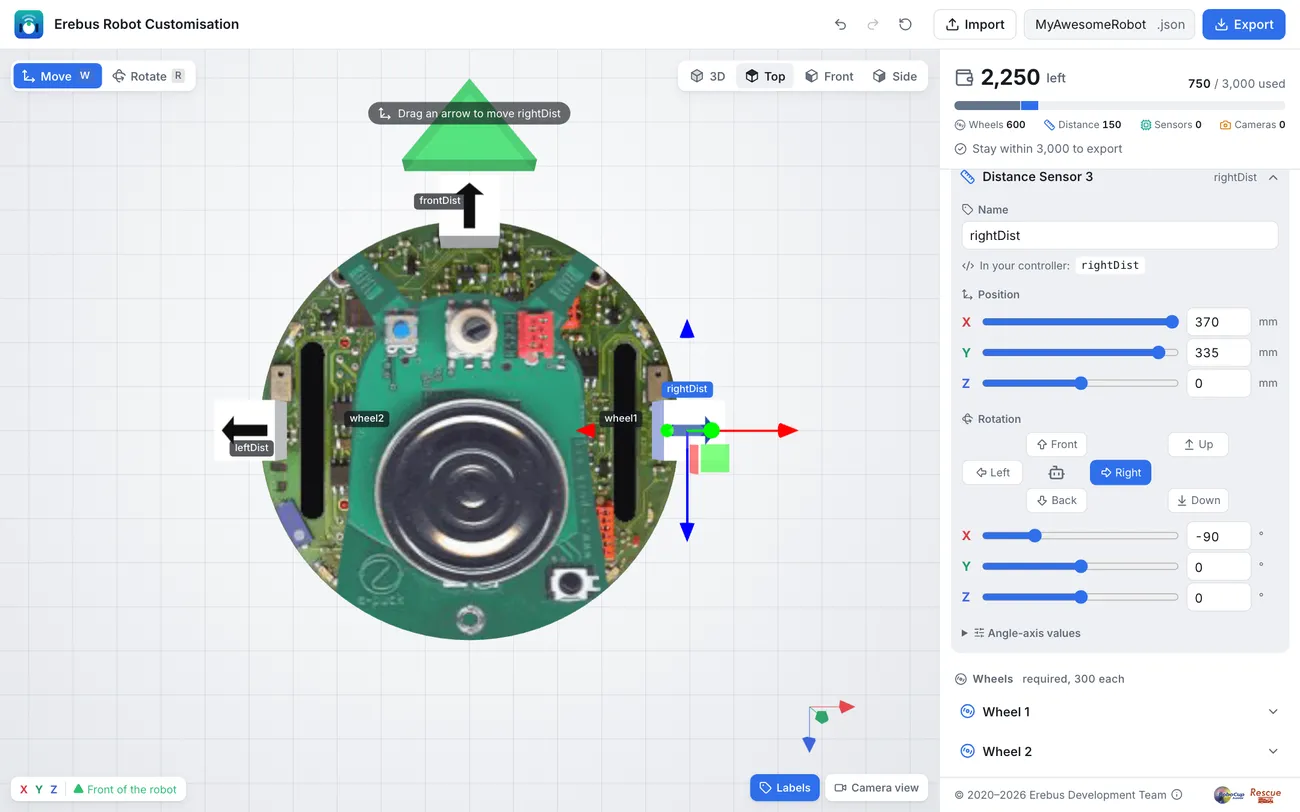
距离传感器测量它前方第一个物体的距离,单位为米,最远 0.8 m。入门机器人有三个距离传感器:leftDist、frontDist 和 rightDist,分别朝向左方、前方和右方。
from controller import Robot
robot = Robot()timeStep = int(robot.getBasicTimeStep())
frontDist = robot.getDevice("frontDist")  # Get the sensor by namefrontDist.enable(timeStep)                 # Enable it
while robot.step(timeStep) != -1:    print("Front:", round(frontDist.getValue(), 3), "m")
#include <iostream>#include <webots/Robot.hpp>#include <webots/DistanceSensor.hpp>
using namespace webots;using namespace std;
int main() { Robot *robot = new Robot(); int timeStep = (int)robot->getBasicTimeStep();
DistanceSensor *frontDist = robot->getDistanceSensor("frontDist"); // Get the sensor by name frontDist->enable(timeStep); // Enable it
while (robot->step(timeStep) != -1) cout << "Front: " << frontDist->getValue() << " m" << endl;
delete robot; return 0;}一个地块宽 12 cm,所以当机器人位于地块中央时,它侧面的墙大约在 5 cm 之外。下面的程序会检查三个传感器,并打印出哪些传感器看到了墙:
from controller import Robot
robot = Robot()timeStep = int(robot.getBasicTimeStep())
# Keep the sensors in a dictionary, to use them by namesensors = {}for name in ["leftDist", "frontDist", "rightDist"]:    sensors[name] = robot.getDevice(name)    sensors[name].enable(timeStep)
WALL = 0.07  # Closer than 7 cm counts as a wall next to the robot
while robot.step(timeStep) != -1:    walls = [name for name, sensor in sensors.items() if sensor.getValue() < WALL]    print("Walls:", walls)
#include <iostream>#include <string>#include <vector>#include <webots/Robot.hpp>#include <webots/DistanceSensor.hpp>
using namespace webots;using namespace std;
int main() { Robot *robot = new Robot(); int timeStep = (int)robot->getBasicTimeStep();
vector<string> names = {"leftDist", "frontDist", "rightDist"}; vector<DistanceSensor *> sensors; for (const string &name : names) { sensors.push_back(robot->getDistanceSensor(name)); sensors.back()->enable(timeStep); }
const double WALL = 0.07; // Closer than 7 cm counts as a wall next to the robot
while (robot->step(timeStep) != -1) { cout << "Walls:"; for (size_t i = 0; i < sensors.size(); i++) if (sensors[i]->getValue() < WALL) cout << " " << names[i]; cout << endl; }
delete robot; return 0;}传感器是从它们在机器人上的位置开始测量的,而不是从机器人的中心。把机器人放在墙边打印这些数值,然后选出你自己的阈值。

Erebus 是 RoboCupJunior Rescue 的一部分。
新闻、活动和队伍文档:RCJ Rescue 社区网站
© 2020–2026 Erebus Development Team