

 Bahasa Indonesia
 Deutsch
 English
 Español
 Français
 Português (Brasil)
 Türkçe
 ไทย
 中文(繁體)
 日本語
 한국어
移动
机器人有两个车轮,每个车轮都有自己的电机:在入门机器人上分别是 left wheel motor 和 right wheel motor。你通过设置每个车轮的速度来驾驶它:
| 左轮 | 右轮 | 机器人会…… |
|---|---|---|
| 向前 | 向前 | 向前行驶 |
| 向后 | 向后 | 向后行驶 |
| 向后 | 向前 | 原地向左转 |
| 向前 | 向后 | 原地向右转 |
| 快 | 慢 | 向右转弯 |
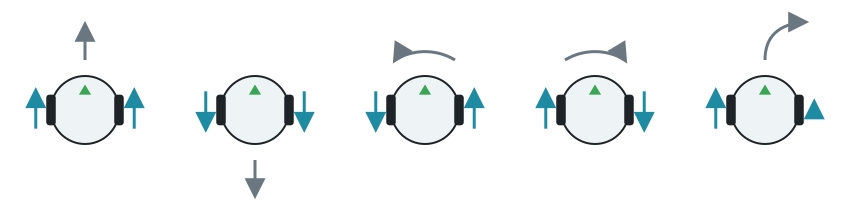
速度的单位是弧度每秒,最大为 6.28(每秒车轮转一圈)。速度为负值时,车轮向后转。
- 按名字获取每个电机。
- 把它的位置设为无穷大,让它可以无限制地转动。
- 设置它的速度。
电机会保持你最后设置的速度,所以在程序做其他事情时,机器人会继续移动。下面的程序让机器人向前行驶、向后行驶、原地向左转,每个动作持续一秒:
from controller import Robot
robot = Robot()timeStep = int(robot.getBasicTimeStep())maxSpeed = 6.28  # The maximum speed of the wheels, in radians per second
leftWheel = robot.getDevice("left wheel motor")rightWheel = robot.getDevice("right wheel motor")leftWheel.setPosition(float("inf"))rightWheel.setPosition(float("inf"))
def drive(left, right, seconds):    # Set the speed of each wheel, and keep it for some time    leftWheel.setVelocity(left)    rightWheel.setVelocity(right)    start = robot.getTime()    while robot.step(timeStep) != -1:        if robot.getTime() - start >= seconds:            break
drive(maxSpeed, maxSpeed, 1.0)    # Forwarddrive(-maxSpeed, -maxSpeed, 1.0)  # Backwarddrive(-2.0, 2.0, 1.0)             # Spin to the leftdrive(0, 0, 0.1)                  # Stopprint("Done")
#include <iostream>#include <cmath>#include <webots/Robot.hpp>#include <webots/Motor.hpp>
using namespace webots;
Robot *robot;Motor *leftWheel, *rightWheel;int timeStep;const double maxSpeed = 6.28; // The maximum speed of the wheels, in radians per second
// Set the speed of each wheel, and keep it for some timevoid drive(double left, double right, double seconds) { leftWheel->setVelocity(left); rightWheel->setVelocity(right); double start = robot->getTime(); while (robot->step(timeStep) != -1) { if (robot->getTime() - start >= seconds) break; }}
int main() { robot = new Robot(); timeStep = (int)robot->getBasicTimeStep();
leftWheel = robot->getMotor("left wheel motor"); rightWheel = robot->getMotor("right wheel motor"); leftWheel->setPosition(INFINITY); rightWheel->setPosition(INFINITY);
drive(maxSpeed, maxSpeed, 1.0); // Forward drive(-maxSpeed, -maxSpeed, 1.0); // Backward drive(-2.0, 2.0, 1.0); // Spin to the left drive(0, 0, 0.1); // Stop std::cout << "Done" << std::endl;
delete robot; return 0;}测量车轮转过了多少
Section titled “测量车轮转过了多少”每个电机都有一个位置传感器,也叫编码器,它以弧度为单位记录车轮转过了多少。它可以用来行驶固定的距离。车轮向后转时,计数会减小。
from controller import Robot
robot = Robot()timeStep = int(robot.getBasicTimeStep())
leftWheel = robot.getDevice("left wheel motor")rightWheel = robot.getDevice("right wheel motor")leftWheel.setPosition(float("inf"))rightWheel.setPosition(float("inf"))
# Each wheel has a position sensor, which counts how far it has turnedleftEncoder = leftWheel.getPositionSensor()rightEncoder = rightWheel.getPositionSensor()leftEncoder.enable(timeStep)rightEncoder.enable(timeStep)
robot.step(timeStep)  # Step once, so that the sensors have a valuestart = leftEncoder.getValue()
leftWheel.setVelocity(5.0)rightWheel.setVelocity(5.0)
while robot.step(timeStep) != -1:    turned = leftEncoder.getValue() - start    if turned > 10.0:  # Stop after 10 radians        break
leftWheel.setVelocity(0)rightWheel.setVelocity(0)print("Left wheel:", round(leftEncoder.getValue() - start, 2), "rad")
#include <iostream>#include <cmath>#include <webots/Robot.hpp>#include <webots/Motor.hpp>#include <webots/PositionSensor.hpp>
using namespace webots;using namespace std;
int main() { Robot *robot = new Robot(); int timeStep = (int)robot->getBasicTimeStep();
Motor *leftWheel = robot->getMotor("left wheel motor"); Motor *rightWheel = robot->getMotor("right wheel motor"); leftWheel->setPosition(INFINITY); rightWheel->setPosition(INFINITY);
// Each wheel has a position sensor, which counts how far it has turned PositionSensor *leftEncoder = leftWheel->getPositionSensor(); PositionSensor *rightEncoder = rightWheel->getPositionSensor(); leftEncoder->enable(timeStep); rightEncoder->enable(timeStep);
robot->step(timeStep); // Step once, so that the sensors have a value double start = leftEncoder->getValue();
leftWheel->setVelocity(5.0); rightWheel->setVelocity(5.0);
while (robot->step(timeStep) != -1) { double turned = leftEncoder->getValue() - start; if (turned > 10.0) // Stop after 10 radians break; }
leftWheel->setVelocity(0); rightWheel->setVelocity(0); cout << "Left wheel: " << leftEncoder->getValue() - start << " rad" << endl;
delete robot; return 0;}按时间控制移动很简单,但结果会随速度而变化。编码器测量的是移动本身,所以更可靠。要想精确转向,陀螺仪效果更好。
接下来,学习如何读取传感器。

Erebus 是 RoboCupJunior Rescue 的一部分。
新闻、活动和队伍文档:RCJ Rescue 社区网站
© 2020–2026 Erebus Development Team