

 Bahasa Indonesia
 Deutsch
 English
 Español
 Français
 Português (Brasil)
 ไทย
 中文(简体)
 中文(繁體)
 日本語
 한국어
Mesafe sensörü
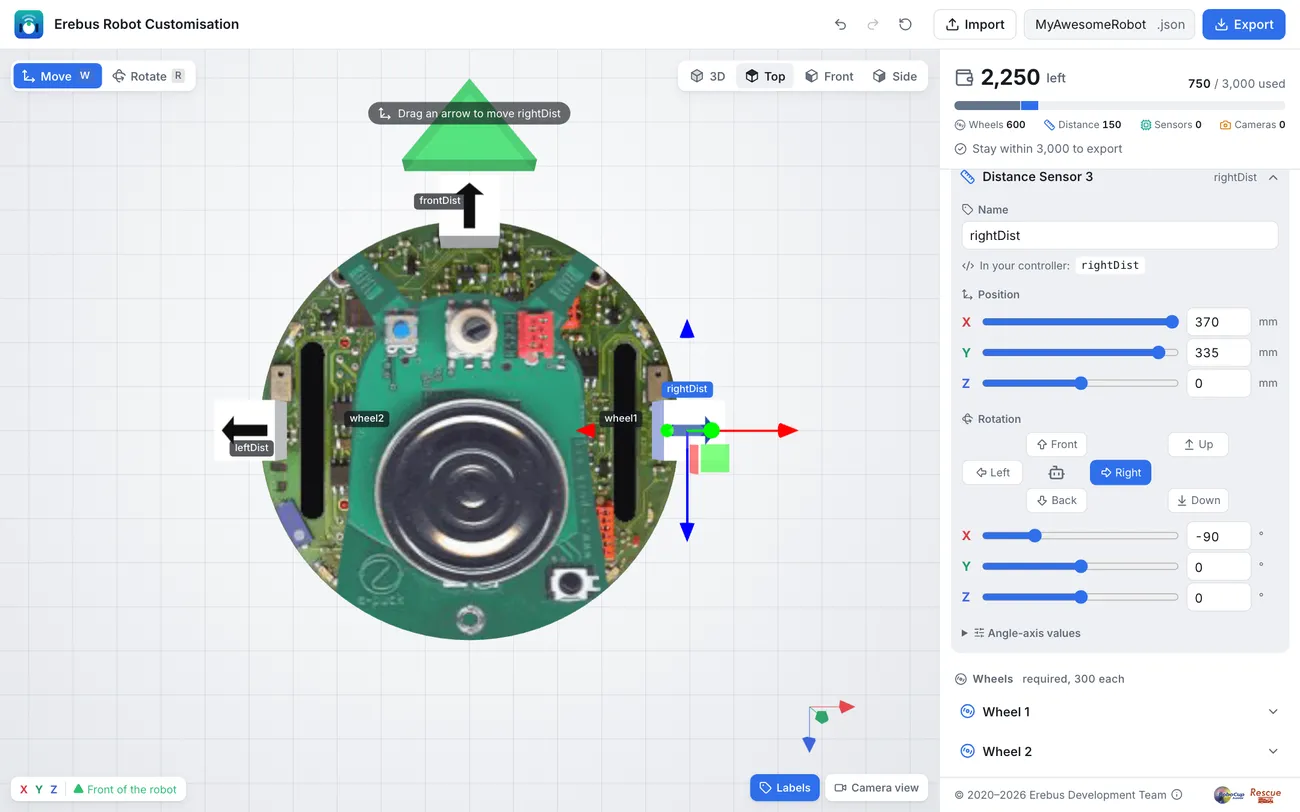
Mesafe sensörü, önündeki ilk nesneye olan uzaklığı metre cinsinden, en fazla 0,8 m’ye kadar ölçer. Başlangıç robotunda üç tane vardır: sola, öne ve sağa bakan leftDist, frontDist ve rightDist.
Sensörü okuma
Bölüm başlığı “Sensörü okuma”from controller import Robot
robot = Robot()timeStep = int(robot.getBasicTimeStep())
frontDist = robot.getDevice("frontDist") # Get the sensor by namefrontDist.enable(timeStep) # Enable it
while robot.step(timeStep) != -1: print("Front:", round(frontDist.getValue(), 3), "m")#include <iostream>#include <webots/Robot.hpp>#include <webots/DistanceSensor.hpp>
using namespace webots;using namespace std;
int main() { Robot *robot = new Robot(); int timeStep = (int)robot->getBasicTimeStep();
DistanceSensor *frontDist = robot->getDistanceSensor("frontDist"); // Get the sensor by name frontDist->enable(timeStep); // Enable it
while (robot->step(timeStep) != -1) cout << "Front: " << frontDist->getValue() << " m" << endl;
delete robot; return 0;}Duvarları bulma
Bölüm başlığı “Duvarları bulma”Bir kare 12 cm genişliğindedir. Bu yüzden robot bir karenin ortasındayken yanındaki bir duvar yaklaşık 5 cm uzaktadır. Bu program üç sensörü kontrol eder ve hangilerinin duvar gördüğünü yazdırır:
from controller import Robot
robot = Robot()timeStep = int(robot.getBasicTimeStep())
# Keep the sensors in a dictionary, to use them by namesensors = {}for name in ["leftDist", "frontDist", "rightDist"]:    sensors[name] = robot.getDevice(name)    sensors[name].enable(timeStep)
WALL = 0.07  # Closer than 7 cm counts as a wall next to the robot
while robot.step(timeStep) != -1:    walls = [name for name, sensor in sensors.items() if sensor.getValue() < WALL]    print("Walls:", walls)
#include <iostream>#include <string>#include <vector>#include <webots/Robot.hpp>#include <webots/DistanceSensor.hpp>
using namespace webots;using namespace std;
int main() { Robot *robot = new Robot(); int timeStep = (int)robot->getBasicTimeStep();
vector<string> names = {"leftDist", "frontDist", "rightDist"}; vector<DistanceSensor *> sensors; for (const string &name : names) { sensors.push_back(robot->getDistanceSensor(name)); sensors.back()->enable(timeStep); }
const double WALL = 0.07; // Closer than 7 cm counts as a wall next to the robot
while (robot->step(timeStep) != -1) { cout << "Walls:"; for (size_t i = 0; i < sensors.size(); i++) if (sensors[i]->getValue() < WALL) cout << " " << names[i]; cout << endl; }
delete robot; return 0;}Sensörler, robotun merkezinden değil, robot üzerinde bulundukları yerden ölçer. Kendi eşik değerlerini belirlemek için bir duvarın yanında değerleri yazdır.

Erebus, RoboCupJunior Rescue programının bir parçasıdır.
Haberler, etkinlikler ve takım belgeleri: RCJ Rescue Topluluk Web Sitesi
© 2020–2026 Erebus Development Team