

 Bahasa Indonesia
 Deutsch
 English
 Español
 Français
 Português (Brasil)
 ไทย
 中文(简体)
 中文(繁體)
 日本語
 한국어
Labirentte yol bul
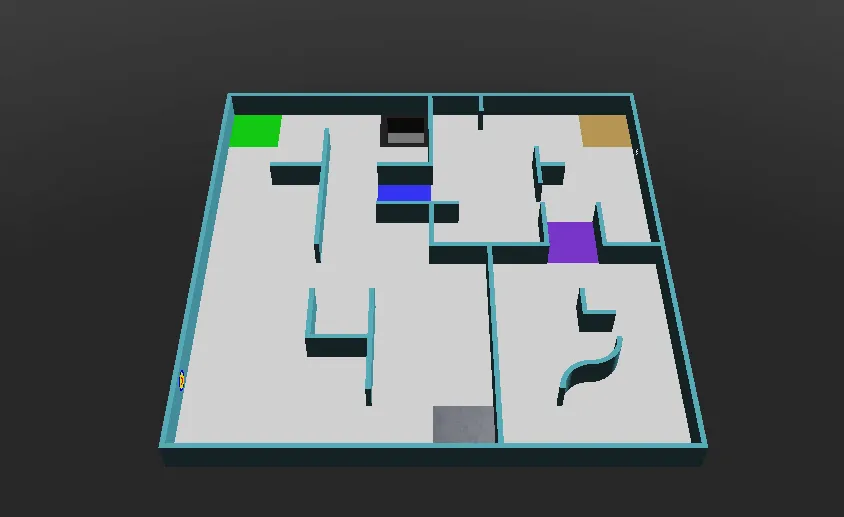
Bu eğitimde adım adım eksiksiz bir program yazacaksın. Robot, duvarlardan ve çukurlardan kaçınarak labirentte dolaşır ve duvar işaretine benzeyen her şeyi bildirir. Bu, İlk çalıştırman sayfasında çalıştırdığın programdır.
Program, başlangıç robotunu ve Hareket ile Sensörler sayfalarında öğrendiklerini kullanır.
Programın tamamı: maze.py · maze.cpp
Programı şuna benzeyen world1.wbt üzerinde çalıştır:
Adım adım
Bölüm başlığı “Adım adım”1. Hazırlık
Bölüm başlığı “1. Hazırlık”Program önce robotu oluşturur, tekerlek motorlarını alır ve motorların sınırsız dönmesine izin verir. speeds her tekerleğin hızını tutar; programın geri kalanı bu değerleri değiştirir. reported, robotun daha önce nerelerde işaret bildirdiğini hatırlar.
from controller import Robotimport structimport numpy as npimport cv2 as cv
robot = Robot()timeStep = 32         # Milliseconds between stepsmaxVelocity = 6.28    # The maximum speed of the wheels, in radians per second
leftWheel = robot.getDevice("left wheel motor")rightWheel = robot.getDevice("right wheel motor")leftWheel.setPosition(float("inf"))   # Let the wheels turn without limitrightWheel.setPosition(float("inf"))
speeds = [maxVelocity, maxVelocity]   # [left wheel speed, right wheel speed]reported = []                         # Positions where a token has already been reported
#include <array>#include <cmath>#include <cstring>#include <vector>#include <opencv2/opencv.hpp>#include <webots/Robot.hpp>#include <webots/Motor.hpp>#include <webots/DistanceSensor.hpp>#include <webots/Camera.hpp>#include <webots/Emitter.hpp>#include <webots/GPS.hpp>
using namespace webots;using namespace std;
Robot *robot = new Robot();const int timeStep = 32; // Milliseconds between stepsconst double maxVelocity = 6.28; // The maximum speed of the wheels, in radians per second
Motor *leftWheel = robot->getMotor("left wheel motor");Motor *rightWheel = robot->getMotor("right wheel motor");
double speeds[2] = {maxVelocity, maxVelocity}; // {left wheel speed, right wheel speed}vector<array<int, 2>> reported; // Positions where a token has already been reported2. Sensörler
Bölüm başlığı “2. Sensörler”Sonra başlangıç robotunun sensörlerini alır ve etkinleştirir:
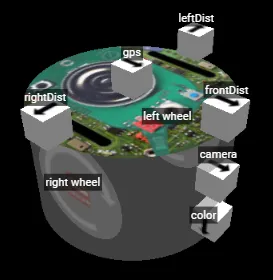
leftDist = robot.getDevice("leftDist")frontDist = robot.getDevice("frontDist")rightDist = robot.getDevice("rightDist")camera = robot.getDevice("camera")colorSensor = robot.getDevice("color")gps = robot.getDevice("gps")emitter = robot.getDevice("emitter")  # The emitter does not need to be enabled
for sensor in [leftDist, frontDist, rightDist, camera, colorSensor, gps]:    sensor.enable(timeStep)
DistanceSensor *leftDist = robot->getDistanceSensor("leftDist");DistanceSensor *frontDist = robot->getDistanceSensor("frontDist");DistanceSensor *rightDist = robot->getDistanceSensor("rightDist");Camera *camera = robot->getCamera("camera");Camera *colorSensor = robot->getCamera("color");GPS *gps = robot->getGPS("gps");Emitter *emitter = robot->getEmitter("emitter"); // The emitter does not need to be enabled
void enableSensors() { leftDist->enable(timeStep); frontDist->enable(timeStep); rightDist->enable(timeStep); camera->enable(timeStep); colorSensor->enable(timeStep); gps->enable(timeStep);}3. Hareketler
Bölüm başlığı “3. Hareketler”Bu fonksiyonlar, robotun dönüş yapması ve olduğu yerde dönmesi için hızları değiştirir. delay, robotun belirli bir milisaniye boyunca aynı şeyi yapmaya devam etmesini sağlar; getBrightness ise renk sensörünü 0 (siyah) ile 255 (beyaz) arasında tek bir değer olarak okur.
def turnRight():    speeds[0] = 0.6 * maxVelocity    speeds[1] = -0.2 * maxVelocity
def turnLeft():    speeds[0] = -0.2 * maxVelocity    speeds[1] = 0.6 * maxVelocity
def spin():    speeds[0] = 0.6 * maxVelocity    speeds[1] = -0.6 * maxVelocity
def delay(ms):    start = robot.getTime()    while robot.step(timeStep) != -1:        if (robot.getTime() - start) * 1000 > ms:            break
def getBrightness():    image = colorSensor.getImage()    return colorSensor.imageGetGray(image, colorSensor.getWidth(), 0, 0)  # 0 (black) to 255 (white)
void turnRight() { speeds[0] = 0.6 * maxVelocity; speeds[1] = -0.2 * maxVelocity;}
void turnLeft() { speeds[0] = -0.2 * maxVelocity; speeds[1] = 0.6 * maxVelocity;}
void spin() { speeds[0] = 0.6 * maxVelocity; speeds[1] = -0.6 * maxVelocity;}
void delay(int ms) { double start = robot->getTime(); while (robot->step(timeStep) != -1) { if ((robot->getTime() - start) * 1000 > ms) break; }}
int getBrightness() { const unsigned char *image = colorSensor->getImage(); return Camera::imageGetGray(image, colorSensor->getWidth(), 0, 0); // 0 (black) to 255 (white)}4. Bir işareti görme
Bölüm başlığı “4. Bir işareti görme”Bu fonksiyon, kamera görüntüsünde duvar işaretlerini arar. İşaretler, koyu duvarların üzerindeki parlak karelerdir. Bu yüzden fonksiyon, kabaca kare biçiminde olan ve görüntünün kenarına (genellikle zeminin göründüğü yere) değmeyen parlak şekiller arar.
def seesToken(image): height, width = camera.getHeight(), camera.getWidth() image = np.frombuffer(image, np.uint8).reshape((height, width, 4)) # BGRA image for OpenCV gray = cv.cvtColor(image, cv.COLOR_BGRA2GRAY) _, bright = cv.threshold(gray, 200, 255, cv.THRESH_BINARY) # Bright parts in white contours, _ = cv.findContours(bright, cv.RETR_EXTERNAL, cv.CHAIN_APPROX_SIMPLE) for contour in contours: x, y, w, h = cv.boundingRect(contour) if x == 0 or y == 0 or x + w == width or y + h == height: continue # Shapes touching the edge of the image are usually the floor if cv.contourArea(contour) > 40 and 0.65 < w / h < 1.5: return True # A bright, roughly square shape on a wall return Falsebool seesToken(const unsigned char *image) { int height = camera->getHeight(), width = camera->getWidth(); cv::Mat frame(height, width, CV_8UC4, (void *)image); // BGRA image for OpenCV cv::Mat gray, bright; cv::cvtColor(frame, gray, cv::COLOR_BGRA2GRAY); cv::threshold(gray, bright, 200, 255, cv::THRESH_BINARY); // Bright parts in white vector<vector<cv::Point>> contours; cv::findContours(bright, contours, cv::RETR_EXTERNAL, cv::CHAIN_APPROX_SIMPLE); for (const auto &contour : contours) { cv::Rect box = cv::boundingRect(contour); if (box.x == 0 || box.y == 0 || box.x + box.width == width || box.y + box.height == height) continue; // Shapes touching the edge of the image are usually the floor double ratio = (double)box.width / box.height; if (cv::contourArea(contour) > 40 && ratio > 0.65 && ratio < 1.5) return true; // A bright, roughly square shape on a wall } return false;}Bu basit bir başlangıçtır: sembolleri ayırt edemez ve bilişsel hedefleri iyi göremez. Duvar işaretleri eğitimi, nasıl daha iyisini yapabileceğini gösterir.
5. Bildirme
Bölüm başlığı “5. Bildirme”Bir işaretten puan almak için robot 1 saniyeden uzun süre durmalı, sonra işaretin konumunu ve türünü göndermelidir. Her işaretten yalnızca bir kez puan alınabilir ve aynı işareti tekrar bildirmek 5 puana mal olur; bu yüzden program, nerelerde bildirim yaptığını hatırlar. Bu mesajlar İletişim sayfasında açıklanır.
def report(tokenType):    leftWheel.setVelocity(0)  # Stop for more than 1 second    rightWheel.setVelocity(0)    delay(1300)    x = int(gps.getValues()[0] * 100)  # Meters to centimeters    z = int(gps.getValues()[2] * 100)    emitter.send(struct.pack("i i c", x, z, tokenType.encode()))    robot.step(timeStep)    reported.append((x, z))
def alreadyReported():    # Reporting the same token again is a misidentification    x = gps.getValues()[0] * 100    z = gps.getValues()[2] * 100    return any(abs(x - rx) < 12 and abs(z - rz) < 12 for rx, rz in reported)  # Closer than 1 tile
void report(char tokenType) { leftWheel->setVelocity(0); // Stop for more than 1 second rightWheel->setVelocity(0); delay(1300); int x = (int)(gps->getValues()[0] * 100); // Meters to centimeters int z = (int)(gps->getValues()[2] * 100); char message[9]; memcpy(&message[0], &x, 4); memcpy(&message[4], &z, 4); message[8] = tokenType; emitter->send(message, 9); robot->step(timeStep); reported.push_back({x, z});}
bool alreadyReported() { // Reporting the same token again is a misidentification double x = gps->getValues()[0] * 100, z = gps->getValues()[2] * 100; for (const auto &position : reported) if (fabs(x - position[0]) < 12 && fabs(z - position[1]) < 12) // Closer than 1 tile return true; return false;}6. Ana döngü
Bölüm başlığı “6. Ana döngü”Son olarak ana döngü her şeyi bir araya getirir. Her adımda tam hızla başlar, duvarlardan uzaklaşmak için döner, çukurlardan geri döner ve önünde yakın bir duvar olduğunda kameranın gördüğünü bildirir.
while robot.step(timeStep) != -1:    speeds[0] = maxVelocity    speeds[1] = maxVelocity
    if leftDist.getValue() < 0.05:   # Wall on the left: turn right        turnRight()    if rightDist.getValue() < 0.05:  # Wall on the right: turn left        turnLeft()    if frontDist.getValue() < 0.05:  # Wall in front: spin        spin()
    if getBrightness() < 80:         # Black floor: turn away from the hole        spin()        leftWheel.setVelocity(speeds[0])        rightWheel.setVelocity(speeds[1])        delay(600)
    # Close to a wall, and something on it: report it    if frontDist.getValue() < 0.07 and not alreadyReported() and seesToken(camera.getImage()):        report("H")  # The type cannot be told yet, so guess "H"
    leftWheel.setVelocity(speeds[0])    rightWheel.setVelocity(speeds[1])
int main() { enableSensors(); leftWheel->setPosition(INFINITY); // Let the wheels turn without limit rightWheel->setPosition(INFINITY);
while (robot->step(timeStep) != -1) { speeds[0] = maxVelocity; speeds[1] = maxVelocity;
if (leftDist->getValue() < 0.05) // Wall on the left: turn right turnRight(); if (rightDist->getValue() < 0.05) // Wall on the right: turn left turnLeft(); if (frontDist->getValue() < 0.05) // Wall in front: spin spin();
if (getBrightness() < 80) { // Black floor: turn away from the hole spin(); leftWheel->setVelocity(speeds[0]); rightWheel->setVelocity(speeds[1]); delay(600); }
// Close to a wall, and something on it: report it if (frontDist->getValue() < 0.07 && !alreadyReported() && seesToken(camera->getImage())) report('H'); // The type cannot be told yet, so guess 'H'
leftWheel->setVelocity(speeds[0]); rightWheel->setVelocity(speeds[1]); }
delete robot; return 0;}Ne kadar başarılı?
Bölüm başlığı “Ne kadar başarılı?”Bu robot rastgele dolaşır: nerelerde bulunduğunu bilmez ve her kazazedenin türünü tahmin eder. Bazen sıkışır ve oyun onu 20 saniye sonra bir kontrol noktasına geri taşır. İlk program için bu gayet iyi.
- Robotun için en iyi hızları ve mesafeleri bul.
- Bir taraftaki duvarı izle: yan sensörü sabit bir mesafede tut ve ön sensör bir duvar gördüğünde dön.
- Hızı duvarların ne kadar yakın olduğuna göre değiştir.
Sonra İletişim sayfasında puan kazanmayı öğren.

Erebus, RoboCupJunior Rescue programının bir parçasıdır.
Haberler, etkinlikler ve takım belgeleri: RCJ Rescue Topluluk Web Sitesi
© 2020–2026 Erebus Development Team