

 Bahasa Indonesia
 Deutsch
 English
 Español
 Français
 Português (Brasil)
 Türkçe
 中文(简体)
 中文(繁體)
 日本語
 한국어
เซนเซอร์วัดระยะ
เซนเซอร์วัดระยะจะวัดระยะห่างเป็นเมตร ถึงวัตถุชิ้นแรกที่อยู่ด้านหน้า ได้ไกลสุด 0.8 เมตร หุ่นยนต์เริ่มต้นมีเซนเซอร์นี้สามตัว ได้แก่ leftDist, frontDist และ rightDist ซึ่งหันไปทางซ้าย ด้านหน้า และขวา
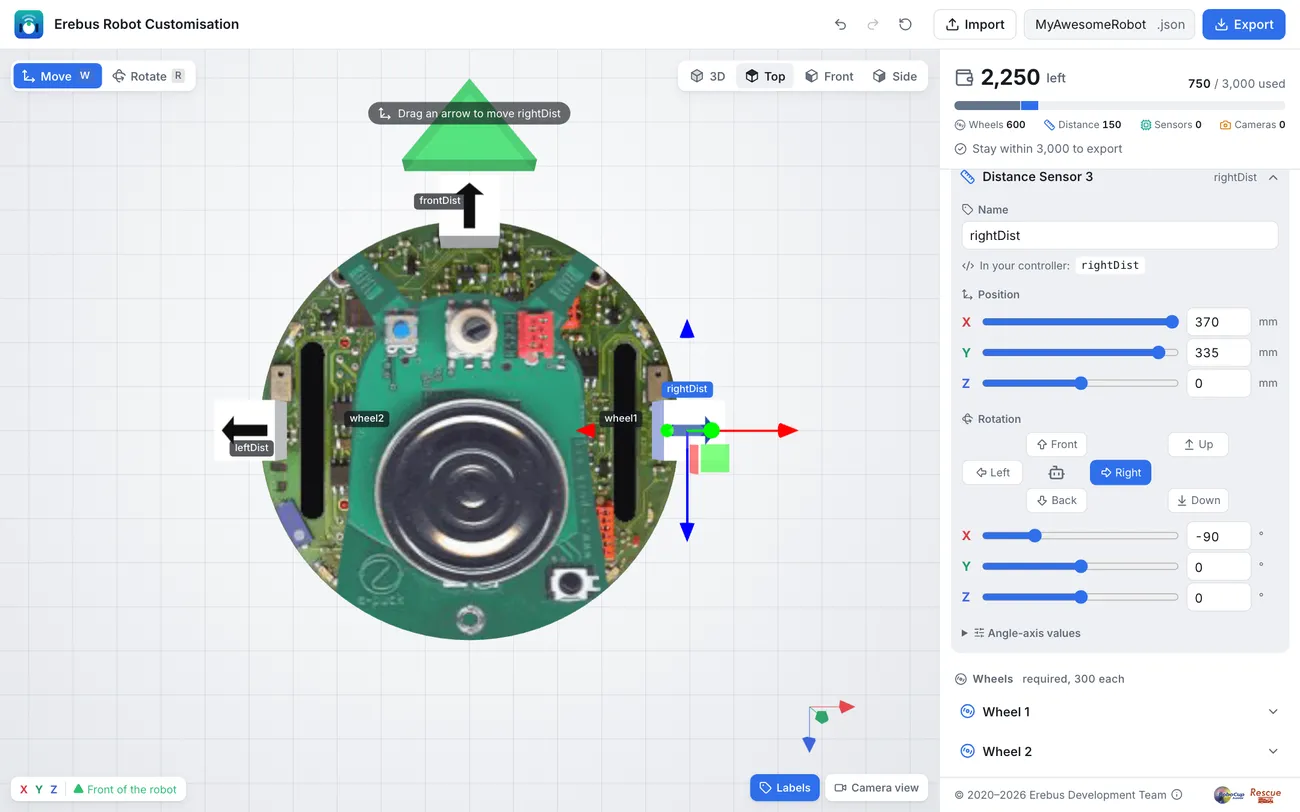
การอ่านค่าเซนเซอร์
หัวข้อที่มีชื่อว่า “การอ่านค่าเซนเซอร์”from controller import Robot
robot = Robot()timeStep = int(robot.getBasicTimeStep())
frontDist = robot.getDevice("frontDist") # Get the sensor by namefrontDist.enable(timeStep) # Enable it
while robot.step(timeStep) != -1: print("Front:", round(frontDist.getValue(), 3), "m")#include <iostream>#include <webots/Robot.hpp>#include <webots/DistanceSensor.hpp>
using namespace webots;using namespace std;
int main() { Robot *robot = new Robot(); int timeStep = (int)robot->getBasicTimeStep();
DistanceSensor *frontDist = robot->getDistanceSensor("frontDist"); // Get the sensor by name frontDist->enable(timeStep); // Enable it
while (robot->step(timeStep) != -1) cout << "Front: " << frontDist->getValue() << " m" << endl;
delete robot; return 0;}การหาผนัง
หัวข้อที่มีชื่อว่า “การหาผนัง”ช่อง (tile) หนึ่งช่องกว้าง 12 ซม. ดังนั้นเมื่อหุ่นยนต์อยู่กลางช่อง ผนังที่อยู่ด้านข้างจะห่างประมาณ 5 ซม. โปรแกรมนี้ตรวจสอบเซนเซอร์ทั้งสามตัว และพิมพ์ว่าตัวใดเห็นผนัง:
from controller import Robot
robot = Robot()timeStep = int(robot.getBasicTimeStep())
# Keep the sensors in a dictionary, to use them by namesensors = {}for name in ["leftDist", "frontDist", "rightDist"]:    sensors[name] = robot.getDevice(name)    sensors[name].enable(timeStep)
WALL = 0.07  # Closer than 7 cm counts as a wall next to the robot
while robot.step(timeStep) != -1:    walls = [name for name, sensor in sensors.items() if sensor.getValue() < WALL]    print("Walls:", walls)
#include <iostream>#include <string>#include <vector>#include <webots/Robot.hpp>#include <webots/DistanceSensor.hpp>
using namespace webots;using namespace std;
int main() { Robot *robot = new Robot(); int timeStep = (int)robot->getBasicTimeStep();
vector<string> names = {"leftDist", "frontDist", "rightDist"}; vector<DistanceSensor *> sensors; for (const string &name : names) { sensors.push_back(robot->getDistanceSensor(name)); sensors.back()->enable(timeStep); }
const double WALL = 0.07; // Closer than 7 cm counts as a wall next to the robot
while (robot->step(timeStep) != -1) { cout << "Walls:"; for (size_t i = 0; i < sensors.size(); i++) if (sensors[i]->getValue() < WALL) cout << " " << names[i]; cout << endl; }
delete robot; return 0;}เซนเซอร์วัดระยะจากตำแหน่งที่ติดตั้งอยู่บนหุ่นยนต์ ไม่ใช่จากจุดกึ่งกลางของหุ่นยนต์ ลองพิมพ์ค่าออกมาเมื่ออยู่ข้างผนัง เพื่อเลือกค่าเกณฑ์ (threshold) ของคุณเอง

Erebus เป็นส่วนหนึ่งของ RoboCupJunior Rescue
ข่าว กิจกรรม และเอกสารของทีม: เว็บไซต์ชุมชน RCJ Rescue
© 2020–2026 Erebus Development Team