

 Bahasa Indonesia
 Deutsch
 English
 Español
 Français
 Português (Brasil)
 Türkçe
 中文(简体)
 中文(繁體)
 日本語
 한국어
กล้อง RGB
กล้องให้ภาพของสิ่งที่อยู่ด้านหน้า คุณต้องใช้กล้องเพื่อค้นหาและอ่านสัญลักษณ์บนผนัง หุ่นยนต์เริ่มต้นมีกล้องหนึ่งตัวชื่อ camera ขนาด 64 × 40 พิกเซล
การอ่านพิกเซล
หัวข้อที่มีชื่อว่า “การอ่านพิกเซล”ภาพคือตารางของพิกเซล แต่ละพิกเซลมีค่าสีแดง เขียว และน้ำเงิน ตั้งแต่ 0 ถึง 255 โดย (0, 0, 0) คือสีดำ และ (255, 255, 255) คือสีขาว
from controller import Robot
robot = Robot()timeStep = int(robot.getBasicTimeStep())
camera = robot.getDevice("camera")camera.enable(timeStep)width = camera.getWidth()height = camera.getHeight()print("The camera has", width, "x", height, "pixels")
while robot.step(timeStep) != -1:    image = camera.getImage()    # The colour of the pixel in the center of the image    r = camera.imageGetRed(image, width, width // 2, height // 2)    g = camera.imageGetGreen(image, width, width // 2, height // 2)    b = camera.imageGetBlue(image, width, width // 2, height // 2)    print("Center:", r, g, b)
#include <iostream>#include <webots/Robot.hpp>#include <webots/Camera.hpp>
using namespace webots;using namespace std;
int main() { Robot *robot = new Robot(); int timeStep = (int)robot->getBasicTimeStep();
Camera *camera = robot->getCamera("camera"); camera->enable(timeStep); int width = camera->getWidth(); int height = camera->getHeight(); cout << "The camera has " << width << " x " << height << " pixels" << endl;
while (robot->step(timeStep) != -1) { const unsigned char *image = camera->getImage(); // The colour of the pixel in the center of the image int r = Camera::imageGetRed(image, width, width / 2, height / 2); int g = Camera::imageGetGreen(image, width, width / 2, height / 2); int b = Camera::imageGetBlue(image, width, width / 2, height / 2); cout << "Center: " << r << " " << g << " " << b << endl; }
delete robot; return 0;}การใช้ OpenCV
หัวข้อที่มีชื่อว่า “การใช้ OpenCV”OpenCV เป็นไลบรารีสำหรับประมวลผลภาพ เช่น ค้นหารูปทรง เปรียบเทียบสี และอื่น ๆ อีกมาก ภาพของ Webots มี 4 ค่าต่อพิกเซล เรียงลำดับแบบ BGRA ซึ่ง OpenCV ใช้ได้โดยตรง โปรแกรมนี้แสดงภาพและส่วนที่สว่างของภาพในสองหน้าต่าง:
from controller import Robotimport cv2import numpy as np
robot = Robot()timeStep = int(robot.getBasicTimeStep())
camera = robot.getDevice("camera")camera.enable(timeStep)
while robot.step(timeStep) != -1:    # Webots images have 4 channels per pixel, in BGRA order    image = np.frombuffer(camera.getImage(), np.uint8).reshape((camera.getHeight(), camera.getWidth(), 4))    frame = cv2.cvtColor(image, cv2.COLOR_BGRA2BGR)    gray = cv2.cvtColor(frame, cv2.COLOR_BGR2GRAY)    _, thresh = cv2.threshold(gray, 200, 255, cv2.THRESH_BINARY)  # Bright parts in white
    cv2.imshow("camera", cv2.resize(frame, None, fx=4, fy=4, interpolation=cv2.INTER_NEAREST))    cv2.imshow("threshold", cv2.resize(thresh, None, fx=4, fy=4, interpolation=cv2.INTER_NEAREST))    cv2.waitKey(1)  # Shows the windows
#include <opencv2/opencv.hpp>#include <webots/Robot.hpp>#include <webots/Camera.hpp>
using namespace webots;
int main() { Robot *robot = new Robot(); int timeStep = (int)robot->getBasicTimeStep();
Camera *camera = robot->getCamera("camera"); camera->enable(timeStep);
while (robot->step(timeStep) != -1) { // Webots images have 4 channels per pixel, in BGRA order cv::Mat image(camera->getHeight(), camera->getWidth(), CV_8UC4, (void *)camera->getImage()); cv::Mat frame, gray, thresh; cv::cvtColor(image, frame, cv::COLOR_BGRA2BGR); cv::cvtColor(frame, gray, cv::COLOR_BGR2GRAY); cv::threshold(gray, thresh, 200, 255, cv::THRESH_BINARY); // Bright parts in white
cv::Mat big; cv::resize(frame, big, cv::Size(), 4, 4, cv::INTER_NEAREST); cv::imshow("camera", big); cv::resize(thresh, big, cv::Size(), 4, 4, cv::INTER_NEAREST); cv::imshow("threshold", big); cv::waitKey(1); // Shows the windows }
delete robot; return 0;}ทางซ้ายคือภาพจากกล้องของหุ่นยนต์เริ่มต้นที่อยู่หน้าผู้ประสบภัยแบบตัวอักษร ทางขวาคือส่วนที่สว่างของภาพนั้น ตามที่โปรแกรมนี้หาได้
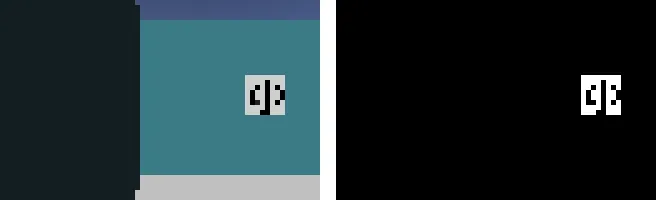
หน้าต่างแบบนี้มีไว้สำหรับทดสอบที่บ้าน ให้ปิดไว้เมื่อแข่งขัน
ความละเอียด
หัวข้อที่มีชื่อว่า “ความละเอียด”ความละเอียดที่สูงขึ้นจะเห็นสัญลักษณ์ได้จากระยะไกลขึ้น แต่ใช้งบประมาณมากกว่าและใช้เวลาประมวลผลนานกว่า คุณเลือกความละเอียดของกล้องแต่ละตัวได้ใน Robot Customizer

Erebus เป็นส่วนหนึ่งของ RoboCupJunior Rescue
ข่าว กิจกรรม และเอกสารของทีม: เว็บไซต์ชุมชน RCJ Rescue
© 2020–2026 Erebus Development Team