

 Bahasa Indonesia
 Deutsch
 Español
 Français
 Português (Brasil)
 Türkçe
 ไทย
 中文(简体)
 中文(繁體)
 日本語
 한국어
RGB Camera
The camera gives an image of what is in front of it. You need it to find and read wall tokens. The starter robot has one camera, named camera, of 64 × 40 pixels.
Reading pixels
Section titled “Reading pixels”An image is a grid of pixels. Each one has a red, green and blue value from 0 to 255, where (0, 0, 0) is black and (255, 255, 255) is white.
from controller import Robot
robot = Robot()timeStep = int(robot.getBasicTimeStep())
camera = robot.getDevice("camera")camera.enable(timeStep)width = camera.getWidth()height = camera.getHeight()print("The camera has", width, "x", height, "pixels")
while robot.step(timeStep) != -1:    image = camera.getImage()    # The colour of the pixel in the center of the image    r = camera.imageGetRed(image, width, width // 2, height // 2)    g = camera.imageGetGreen(image, width, width // 2, height // 2)    b = camera.imageGetBlue(image, width, width // 2, height // 2)    print("Center:", r, g, b)
#include <iostream>#include <webots/Robot.hpp>#include <webots/Camera.hpp>
using namespace webots;using namespace std;
int main() { Robot *robot = new Robot(); int timeStep = (int)robot->getBasicTimeStep();
Camera *camera = robot->getCamera("camera"); camera->enable(timeStep); int width = camera->getWidth(); int height = camera->getHeight(); cout << "The camera has " << width << " x " << height << " pixels" << endl;
while (robot->step(timeStep) != -1) { const unsigned char *image = camera->getImage(); // The colour of the pixel in the center of the image int r = Camera::imageGetRed(image, width, width / 2, height / 2); int g = Camera::imageGetGreen(image, width, width / 2, height / 2); int b = Camera::imageGetBlue(image, width, width / 2, height / 2); cout << "Center: " << r << " " << g << " " << b << endl; }
delete robot; return 0;}Using OpenCV
Section titled “Using OpenCV”OpenCV is a library to process images: find shapes, compare colours and much more. Webots images have 4 values per pixel, in BGRA order, which OpenCV can use directly. This program shows the image, and its bright parts, in two windows:
from controller import Robotimport cv2import numpy as np
robot = Robot()timeStep = int(robot.getBasicTimeStep())
camera = robot.getDevice("camera")camera.enable(timeStep)
while robot.step(timeStep) != -1:    # Webots images have 4 channels per pixel, in BGRA order    image = np.frombuffer(camera.getImage(), np.uint8).reshape((camera.getHeight(), camera.getWidth(), 4))    frame = cv2.cvtColor(image, cv2.COLOR_BGRA2BGR)    gray = cv2.cvtColor(frame, cv2.COLOR_BGR2GRAY)    _, thresh = cv2.threshold(gray, 200, 255, cv2.THRESH_BINARY)  # Bright parts in white
    cv2.imshow("camera", cv2.resize(frame, None, fx=4, fy=4, interpolation=cv2.INTER_NEAREST))    cv2.imshow("threshold", cv2.resize(thresh, None, fx=4, fy=4, interpolation=cv2.INTER_NEAREST))    cv2.waitKey(1)  # Shows the windows
#include <opencv2/opencv.hpp>#include <webots/Robot.hpp>#include <webots/Camera.hpp>
using namespace webots;
int main() { Robot *robot = new Robot(); int timeStep = (int)robot->getBasicTimeStep();
Camera *camera = robot->getCamera("camera"); camera->enable(timeStep);
while (robot->step(timeStep) != -1) { // Webots images have 4 channels per pixel, in BGRA order cv::Mat image(camera->getHeight(), camera->getWidth(), CV_8UC4, (void *)camera->getImage()); cv::Mat frame, gray, thresh; cv::cvtColor(image, frame, cv::COLOR_BGRA2BGR); cv::cvtColor(frame, gray, cv::COLOR_BGR2GRAY); cv::threshold(gray, thresh, 200, 255, cv::THRESH_BINARY); // Bright parts in white
cv::Mat big; cv::resize(frame, big, cv::Size(), 4, 4, cv::INTER_NEAREST); cv::imshow("camera", big); cv::resize(thresh, big, cv::Size(), 4, 4, cv::INTER_NEAREST); cv::imshow("threshold", big); cv::waitKey(1); // Shows the windows }
delete robot; return 0;}On the left, an image of the starter robot’s camera in front of a letter victim. On the right, its bright parts, as this program finds them.
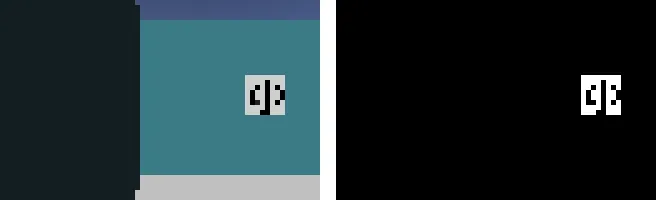
Windows like these are for testing at home: turn them off for the competition.
Resolution
Section titled “Resolution”Higher resolutions see tokens from further away, but cost more and take longer to process. You choose the resolution of each camera in the Robot Customizer.

Erebus is part of RoboCupJunior Rescue.
News, events and team documents: RCJ Rescue Community Website
© 2020–2026 Erebus Development Team